Sign In | Join Free | My infospaceinc.com
China Shenzhen Seninter Precision Machinery Co.,Ltd. logo
Shenzhen Seninter Precision Machinery Co.,Ltd.
"Seninter: Precision in Motion, Power for Automation."
Verified Supplier

1 Years

Shenzhen Seninter Precision Machinery Co.,Ltd.
Trust Seal
Verified Supplier
Credit Check
Supplier Assessment
Contact Now

SYT-RI-70-80

  • 1
  • 2

Model Number : SYT-RI-70-80 CAN

Length : 73mm

Voltage : 24-48VDC

Protocol : EtherCAT / CAN

Brand Name : SENINTER

OD : 80mm

Weight : 0.9kg

Certification : CE ROHS

Max. Speed : 77RPM

Place of Origin : CHINA

Max. Torque : 108N·m

Contact Now

Humanoid Robot Joint Module (Rotary Actuator) Structure – Core Components

Output Flange / Connector – Connects to robot links (e.g., lower leg, forearm), outputs torque and motion.

Torque Sensor (optional but common in high-performance designs) – Ring or spoke type, used for force control / collision detection.

Harmonic Drive – Consists of a wave generator, flexspline, and circular spline; mounted on the motor output shaft.

Frameless Torque Motor – Stator fixed to the housing, rotor connected to the wave generator.

Brake (Safety Holding Brake) – Locks the joint position when power is lost.

Dual Encoders – Motor-side encoder (measures speed/position) and output-side encoder (eliminates reducer backlash error); commonly used for full closed-loop control.

Driver (Servo Drive Board) – Integrated inside the module or in a compact package.

Housing / Cooling Structure – Aluminum alloy body with cable channels.

SYT-RI-70-80

Drawing without brake

SYT-RI-70-80


without brake Parameter Table

Parameter Unit Ratio 51 Ratio 81 Ratio 101 Ratio 121
Gear Ratio - 51 81 101 121
Peak Torque N·m 69 91 102 108
Max Allowable Torque At Average Load (Robot Application) N·m 42 58 61 61
Rated Torque @ 2000RPM (Industrial Application) N·m 32 42 50 50
Peak Output Speed RPM 77 48 40 30
Rated Speed (With 1/2 Rated Torque) RPM 61 38 30 25
Gear Backlash arcsec 20 20 10 10
Rated Power W 500 500 500 500
Supply Voltage V 24–48 24–48 24–48 24–48
Max Continuous Current A 8.4 8.4 8.4 8.4
Rated Current A 6.1 6.1 6.1 6.1
Torque Constant N·m/A 0.118 0.118 0.118 0.118
Encoder Resolution bit 16 16 16 16
Communication Bus - CAN CAN CAN CAN
Hollow Shaft Diameter mm 18 18 18 18
Total Length mm 73±0.5 73±0.5 73±0.5 73±0.5
Mass kg 0.9 0.9 0.9 0.9
Rotational Inertia g·cm² 596.4 596.4 596.4 596.4

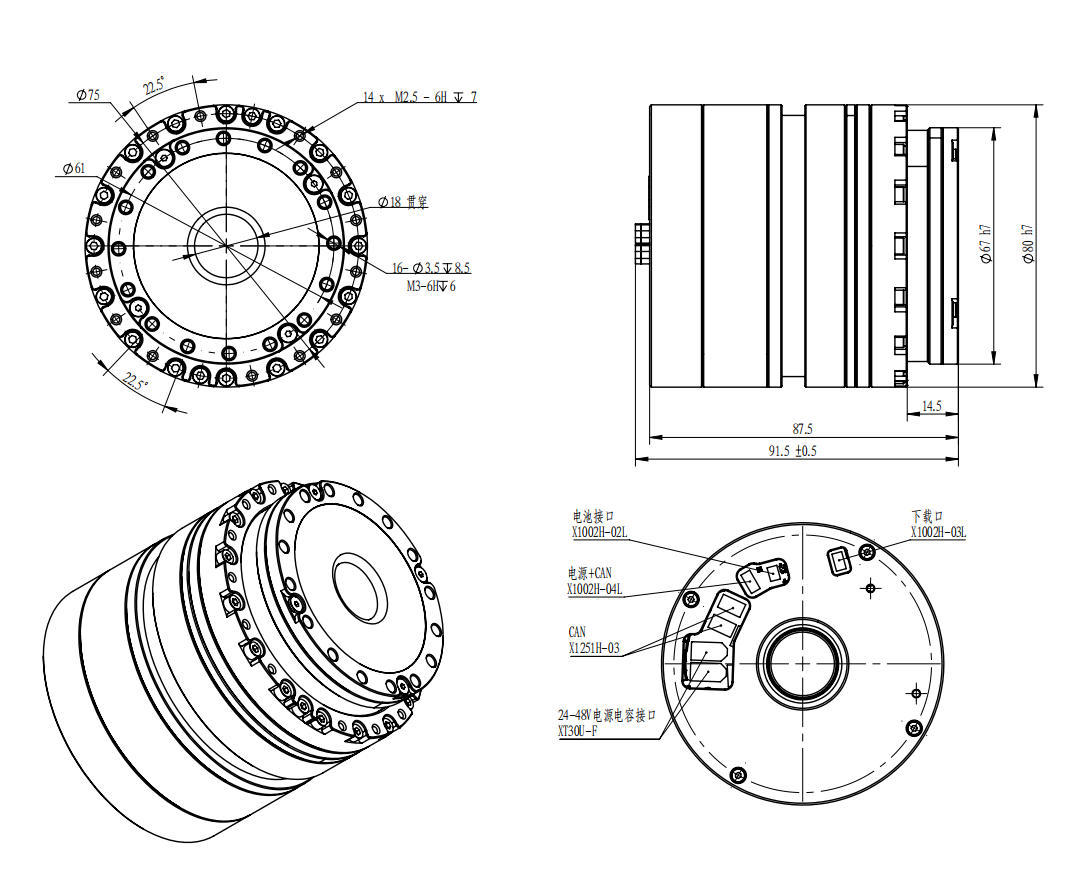
Drawing with brake


SYT-RI-70-80


With brake Parameter Table


Parameter Unit Ratio 51 Ratio 81 Ratio 101 Ratio 121
Gear Ratio - 51 81 101 121
Peak Torque N·m 69 91 102 108
Max Allowable Torque At Average Load (Robot Application) N·m 42 58 61 61
Rated Torque @ 2000RPM (Industrial Application) N·m 32 42 50 50
Peak Output Speed RPM 77 48 40 30
Rated Speed (With 1/2 Rated Torque) RPM 61 38 30 25
Gear Backlash arcsec 20 20 10 10
Rated Power W 500 500 500 500
Supply Voltage V 24–48 24–48 24–48 24–48
Max Continuous Current A 8.4 8.4 8.4 8.4
Rated Current A 6.1 6.1 6.1 6.1
Torque Constant N·m/A 0.118 0.118 0.118 0.118
Encoder Resolution bit 16 16 16 16
Communication Bus - CAN CAN CAN CAN
Hollow Shaft Diameter mm 18 18 18 18
Total Length mm 91.5±0.5 91.5±0.5 91.5±0.5 91.5±0.5
Mass kg 1.11 1.11 1.11 1.11
Rotational Inertia g·cm² 746.7 746.7 746.7 746.7


Quality SYT-RI-70-80 for sale

SYT-RI-70-80 Images

Inquiry Cart 0
Send your message to this supplier
 
*From:
*To: Shenzhen Seninter Precision Machinery Co.,Ltd.
*Subject:
*Message:
Characters Remaining: (0/3000)